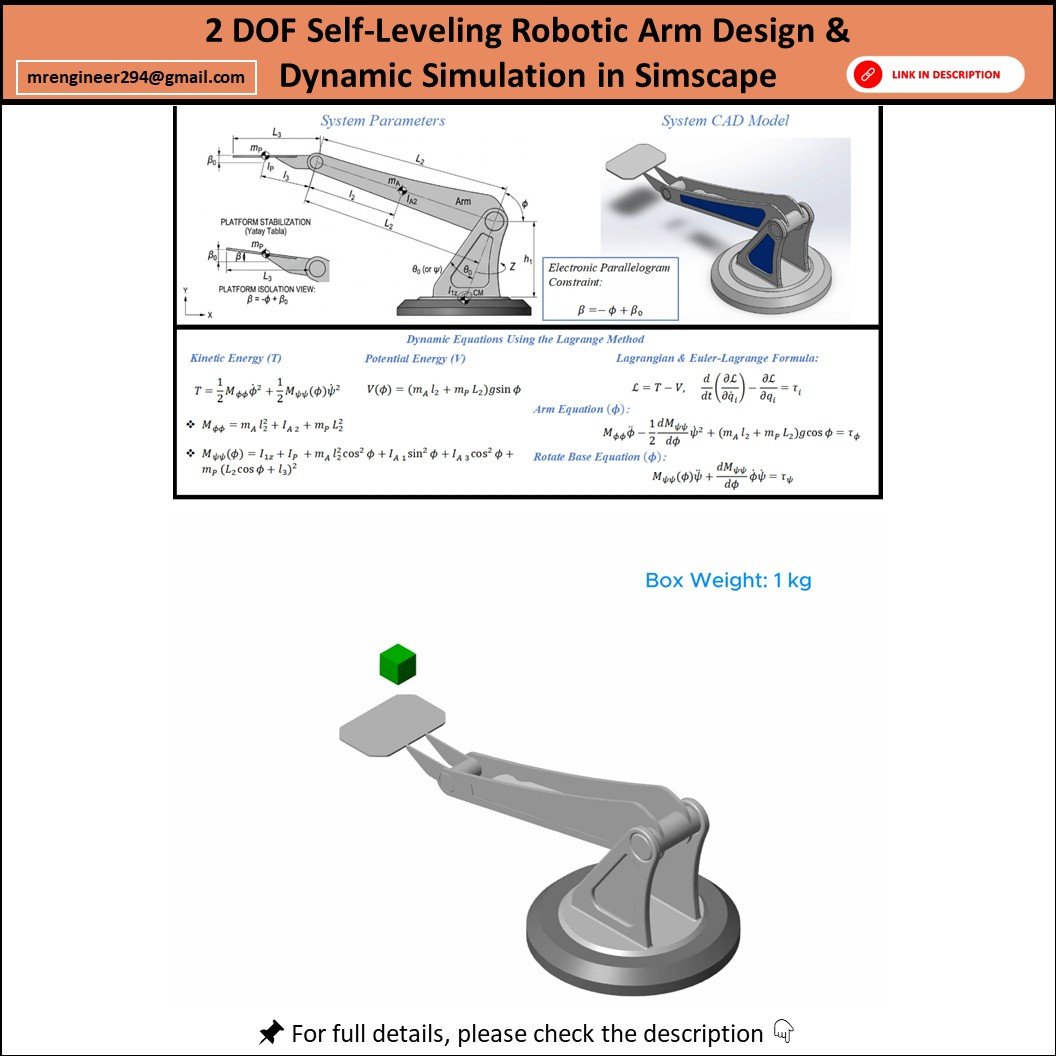
2-DoF Robotic Arm Lagrangian Dynamic Modeling & Simscape Multibody Simulation with Active Platform Stabilization
Explore the dynamic behavior of a 2-DoF robotic arm through mathematical modeling, MATLAB/Simulink simulation, and realistic 3D mechanical simulation using Simscape Multibody.
This project combines Lagrangian dynamic modeling with an active platform stabilization system to demonstrate how robotic arm motion, inertia, gravity, joint dynamics, and applied torques influence the overall system behavior.
The robotic arm is mathematically modeled using the Lagrangian formulation, then implemented in MATLAB/Simulink and integrated with a CAD-based Simscape Multibody model for realistic visualization and dynamic analysis.
⚙️ Project Features
✅ 2-DoF Robotic Arm
✅ Lagrangian Dynamic Modeling
✅ MATLAB & Simulink Implementation
✅ Simscape Multibody 3D Simulation
✅ Active Platform Stabilization
✅ Joint Motion Analysis
✅ Position & Angular Motion Analysis
✅ Torque & Force Analysis
✅ Nonlinear Dynamic Simulation
✅ CAD-Based Mechanical Model
✅ Realistic 3D Robot Animation
✅ Engineering Visualization
📦 What You Get
• MATLAB/Simulink project files
• Simscape Multibody simulation model
• Robotic arm model and related CAD files
• MATLAB scripts and supporting files
• Simulation setup and required project resources
• Documentation/materials included with the project
🎓 Ideal For
• Robotics & Mechatronics Students
• MATLAB & Simulink Learners
• Control Systems Students
• Engineering FYP Projects
• Robotics Research
• Master's & PhD Research
• Dynamic System Modeling
• Mechanical & Robotics Simulation
💡 Applications
Use this project to study robot dynamics, Lagrangian mechanics, MATLAB/Simulink, Simscape Multibody, robotic manipulation, mechanical simulation, and active platform stabilization.
🚀 Ready to take your robotics project to the next level?
Get the complete project today and explore the MATLAB/Simulink, Simscape Multibody, CAD, and supporting files included with the package.
👉 Purchase now and start exploring the complete 2-DoF robotic arm simulation!